Xense Quark N1 Vision-Based Tactile Sensor (Gripper Type)
Vendor: Xense Robotics
Product: N1
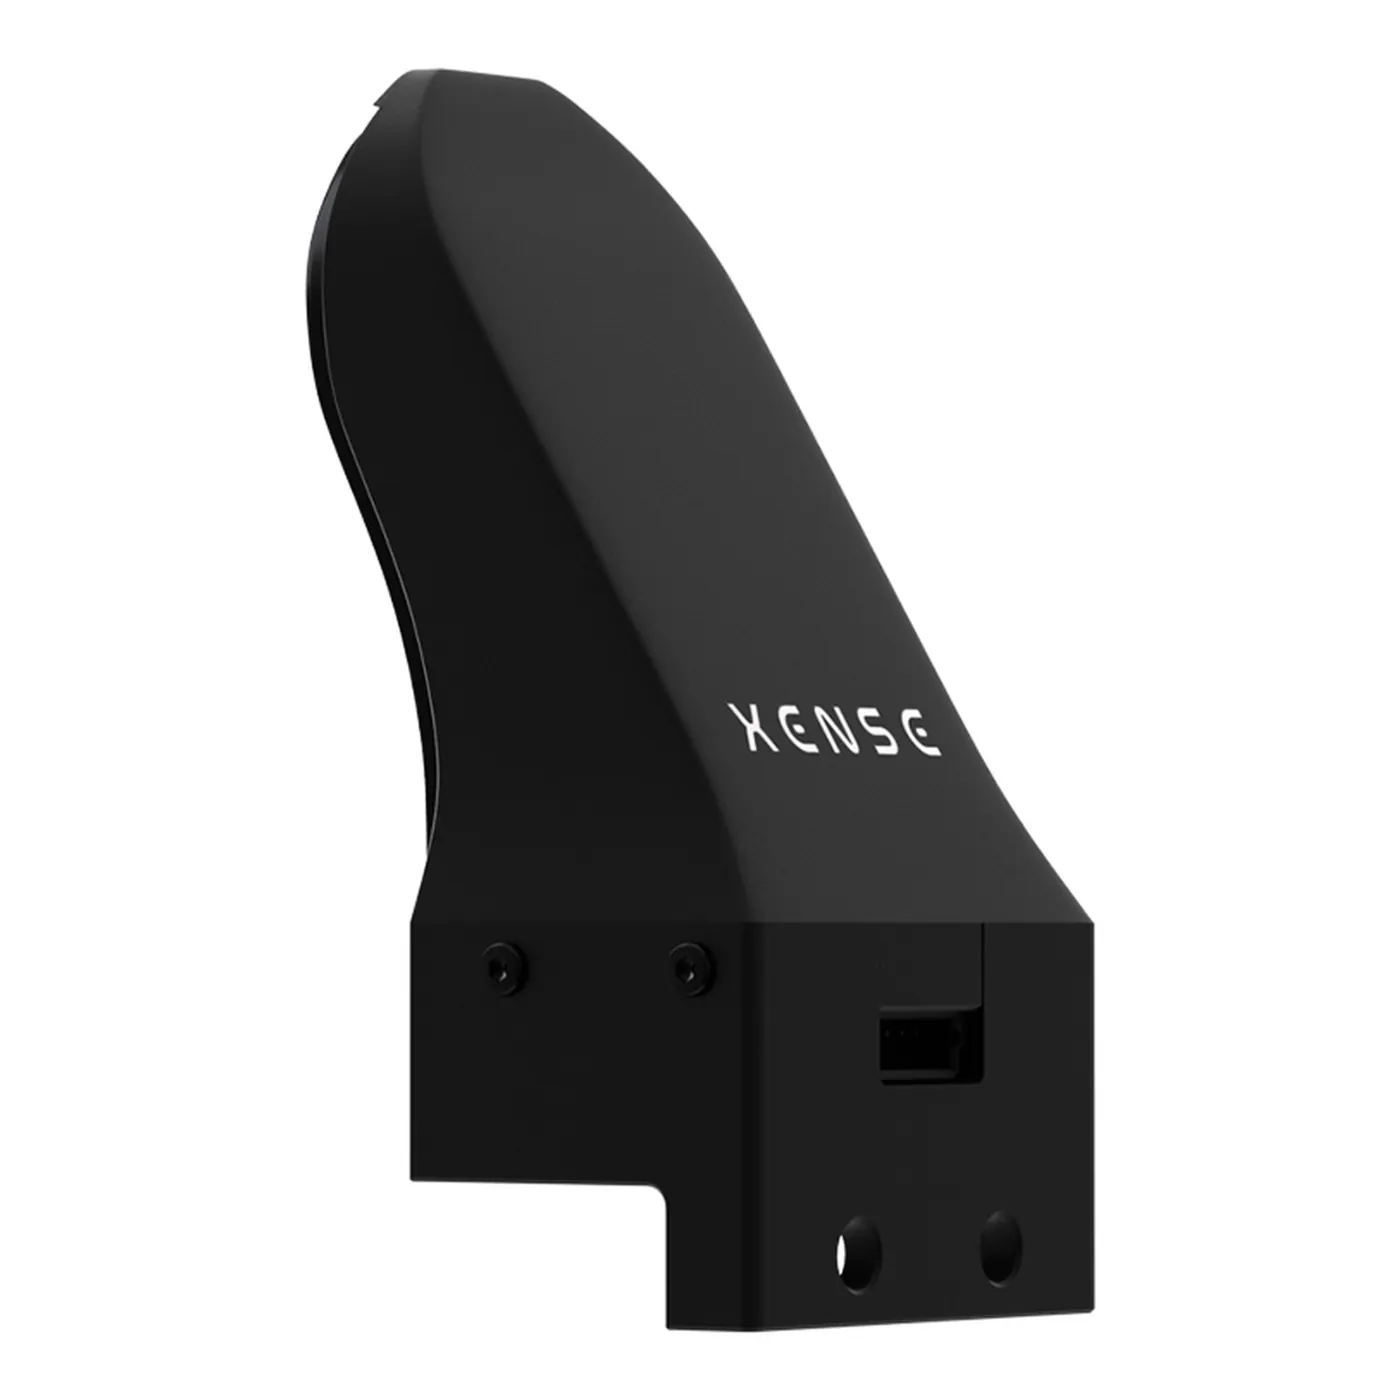
Xense Quark N1 optical vision-based tactile sensor: 18x33 mm sensing area, 0.03 mm spatial resolution, 100 markers/cm2, 2-5 mm flexible layer, 30-150 Hz sampling, UVC, 5 V, 0.6 W; deformation accuracy 0.06 mm, force accuracy 0.02 N; modalities: 3D topography, texture, 6-axis force, distributed force, slip, motion tracking.
| Power | 0.6 W |
| Supply | 5 V |
| Sampling | 30-150 Hz |
| Interface | UVC (USB) |
| Dimensions | 54.3 x 26.7 x 22 mm |
| Modalities | 3D topography, texture, 6-axis force, 3D distributed force, slip, motion tracking |
| Sensing Area | 18(H) x 33(V) mm |
| Flexible Layer | 2-5 mm |
| Force Accuracy | 0.02 N |
| Marker Density | 100 /cm2 |
| Spatial Resolution | 0.03 mm |
| Deformation Accuracy | 0.06 mm |