BLOG
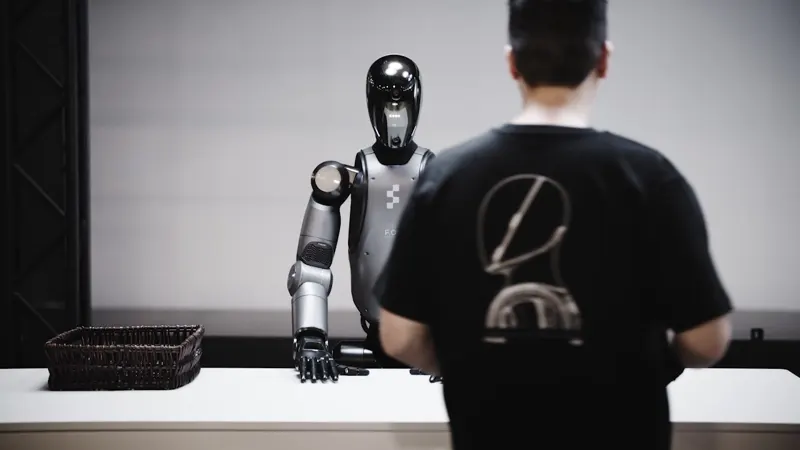
Skild AI's flagship robotic foundation model S1 is built from the ground up as an in-context learner: show it a video demonstration of a task — even an unseen 10-minute long-horizon one — and it executes with no fine-tuning. On unseen tasks, one demonstration ≈ 380 post-training examples; at 100k pre-training hours S1 reaches 66% success vs 9% for language-prompted VLAs.
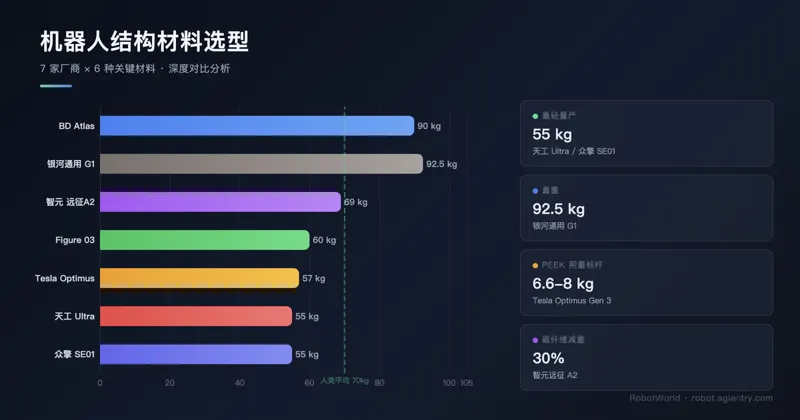
? 7075 + CF + + PEEK 。
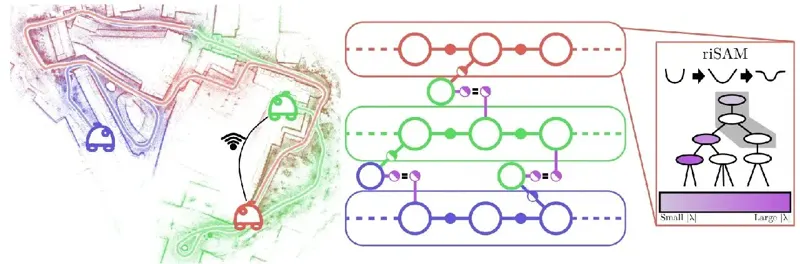
CMU's riMESA combines Consensus ADMM with the incremental robust solver riSAM to unite distribution, incrementality, robustness and weak communication: sharing variables instead of full graphs, dual decay, RWBP that lets stale consensus be overruled by fresh evidence, and non-blocking communication threads. Across 2430 synthetic and 28 real datasets, its gap to Centralized GNC is 7x smaller than DLGBP and 17x smaller than DDF-SAM2, at only ~55 KB/s average bandwidth.
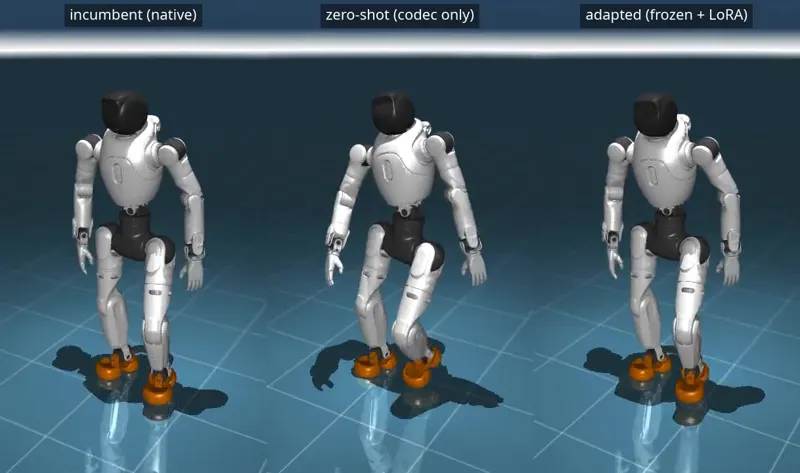
Frozen GEAR-SONIC whole-body controller (Unitree G1) transfers to AgiBot X2 Ultra via closed-form codec + LoRA adapters (0.25% params, 2% compute), beating native training on OOD (69.0% vs 59.0%).
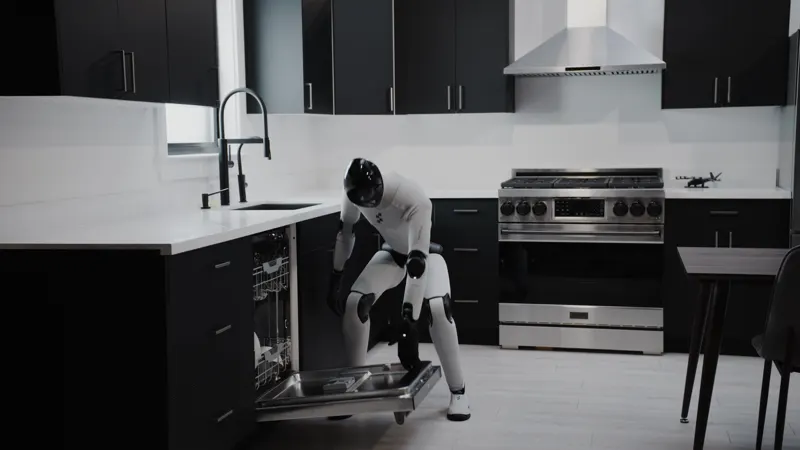
Figure AI's Helix VLA model achieves first humanoid multi-fingered autonomous laundry folding. Same architecture seamlessly transitions from logistics to household chores with data-only change.
Figure AI releases Helix 02, extending single-network control from upper body to whole robot. System 0 trained on 1000+ hours of human motion data replaces 100K lines of hand-engineered C++, enabling 4-minute continuous autonomous loco-manipulation.
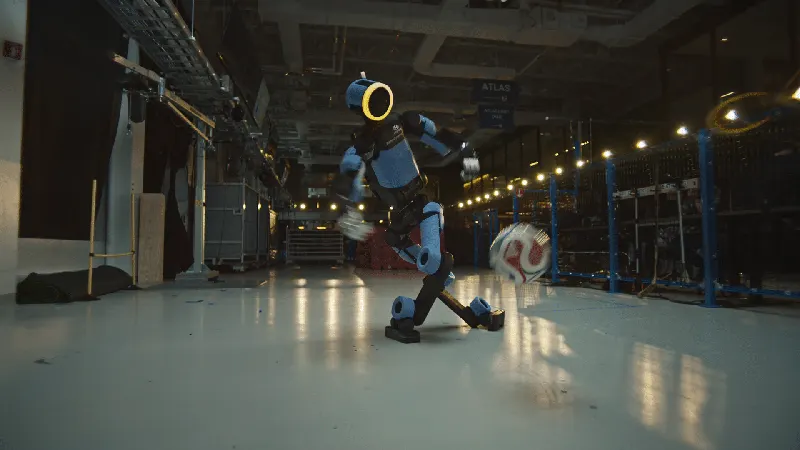
Boston Dynamics teaches Atlas to play football using motion capture + RL for the Ghost Rabona kick. The whole-body coordination required transfers directly to industrial manipulation tasks.
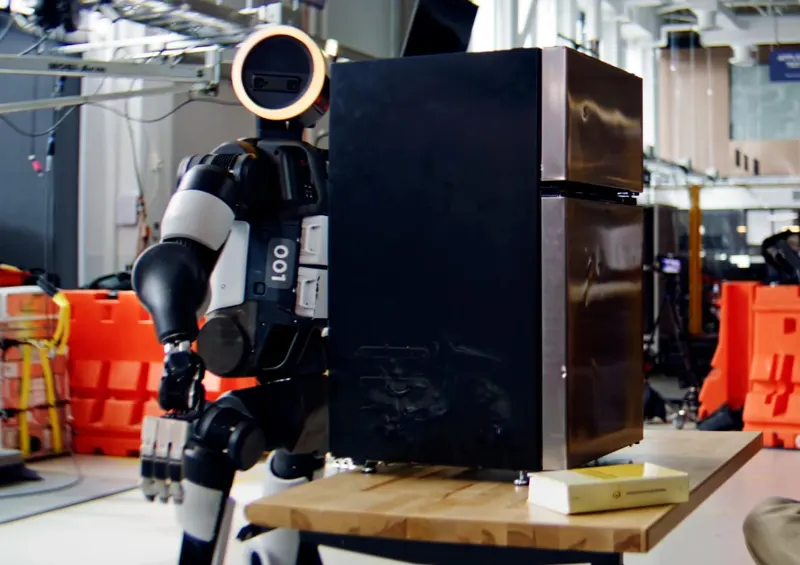
Boston Dynamics shares how Atlas learns whole-body lifting via RL: from reference trajectories and reward design to GPU-scale simulation and real-hardware iteration, demonstrating fundamental building blocks of physical intelligence.
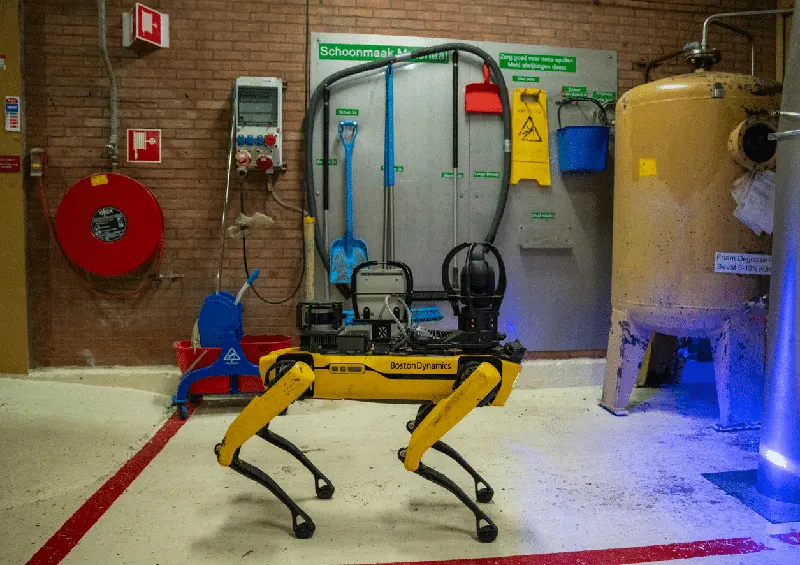
Boston Dynamics integrates Google Gemini into Orbit AIVI-Learning, giving Spot robots advanced reasoning and complex visual analysis for industrial inspections including gauge readings, 5S audits, and pallet counting.
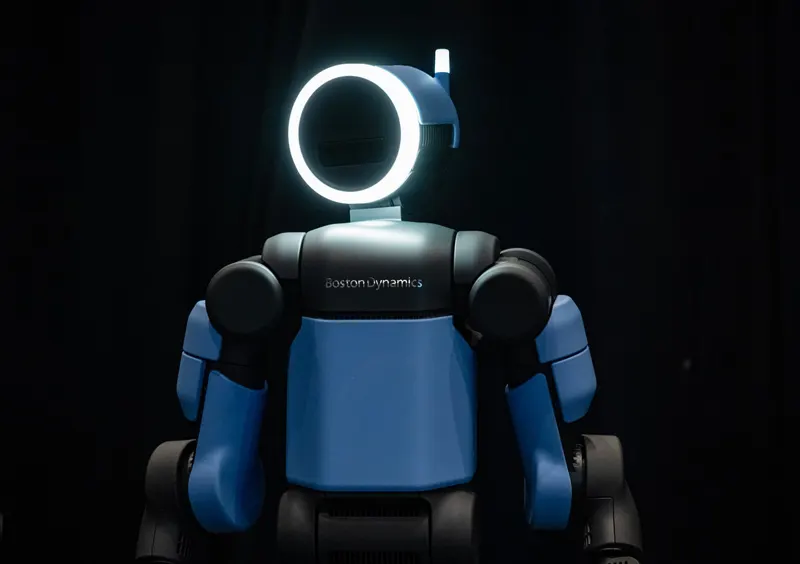
Boston Dynamics traces Atlas' decade-long evolution from hydraulic parkour research platform to electric industrial humanoid. 2026 production-ready Atlas unveiled with Hyundai, already deployed for part sequencing at the Hyundai metaplant.
1X shares 1XWM progress: action-controllable video generation predicts future outcomes of robot actions, shifting policy evaluation from physical experiments to simulated forecasting at scale.
1X announces 25-DOF tendon-driven hands for NEO. Low gear ratios enable force transparency and backdrivability, combined with high-resolution tactile skin, turning every grasp into an experiment — a perception stack, not just an actuator.
As an Amazon Associate, we earn from qualifying purchases.