PyCuVSLAM: GPU-Accelerated Visual SLAM for Python
Loading video
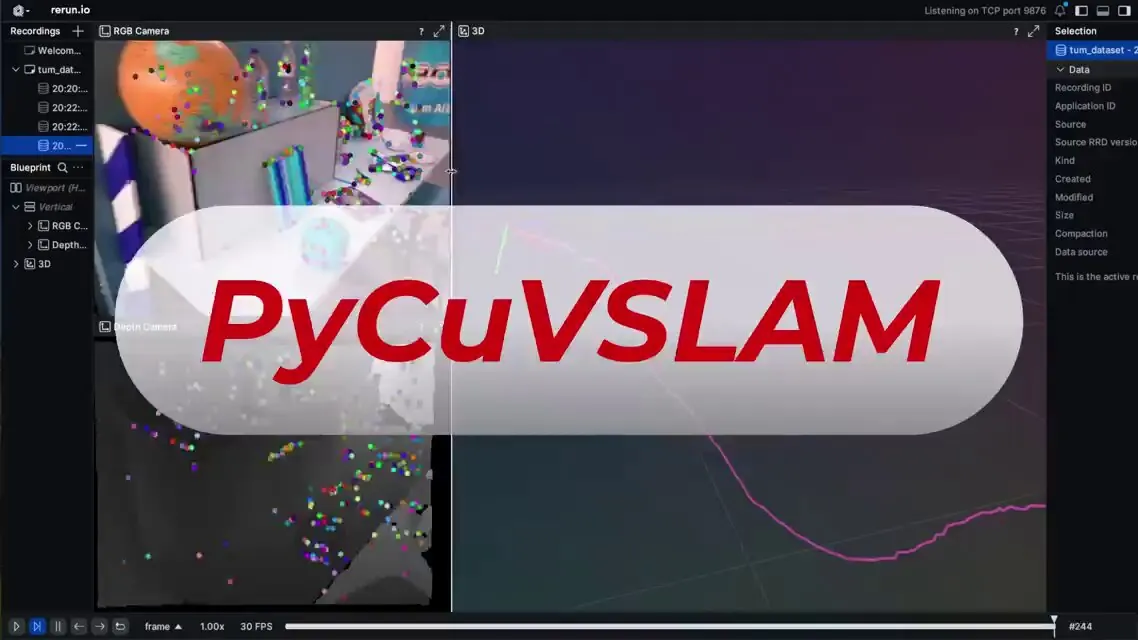
Loading videoPyCuVSLAM exposes NVIDIA cuVSLAM, the GPU-accelerated visual SLAM core behind Isaac ROS Visual SLAM, to plain Python. Tracking stability and trajectory estimation were validated on the TUM RGB-D benchmark.
Category: perception
Author: @tokufxug
Date: 2026-09-21T00:00:00
Duration: 34.399s