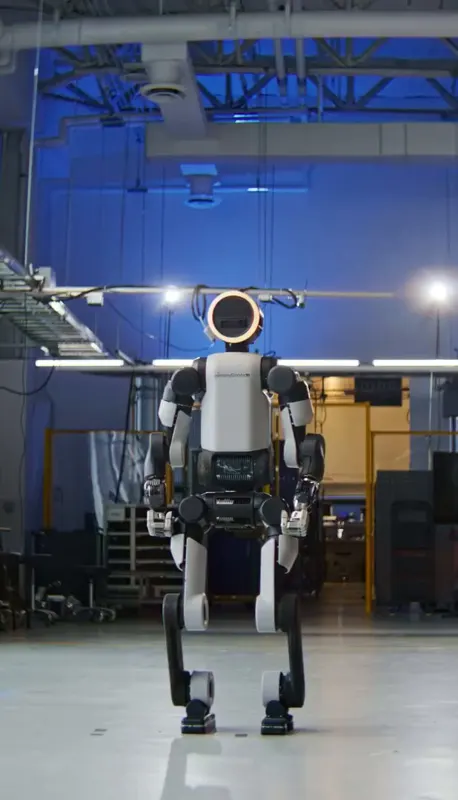
Boston Dynamics equips Atlas with a new 4-finger, 13-DoF hand: official blog explains robot hands built for modern AI and real work
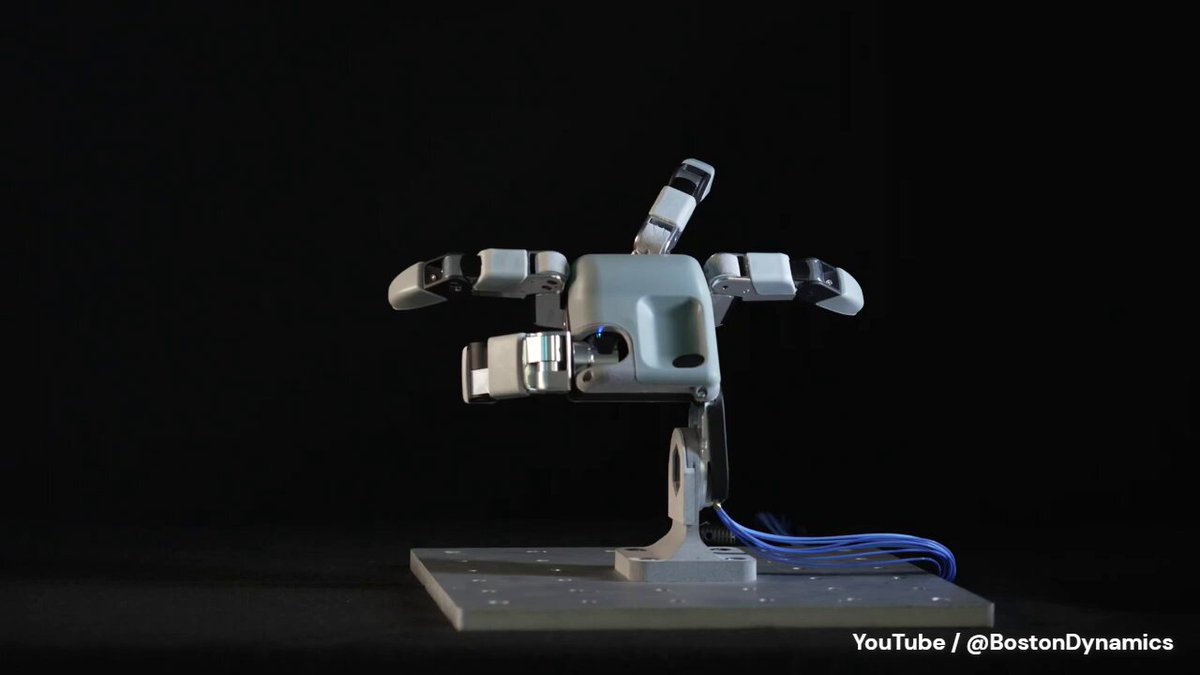
Boston Dynamics unveiled a new-generation dexterous hand for the Atlas humanoid (official blog plus demo video): four fingers, 13 degrees of freedom (double the previous seven), directly actuated, with a 4-DoF thumb enabling fine pinch against the other fingers and 3 DoF per remaining finger, plus pressure-based tactile sensing across fingertips and palm that detects minute contact forces. The video shows picking up a slender drill bit, attaching it to a power drill and boring into wood, turning a nut with the fingers, spinning a drumstick and rolling two golf balls in-hand — covering regrasping, slip correction and tool-trigger operation. Dropping the pinky was a deliberate engineering trade: Alberto Rodriguez, who leads Atlas behavior and manipulation, said the team taped down their own pinkies for full workdays and confirmed the missing finger never blocked the jobs they cared about — buying structural simplicity, lower power, cost, durability and maintainability, with mass manufacturing in mind. Context: Atlas is now training on automotive line tasks at the newly opened RMAC inside Hyundai's Metaplant America (HMGMA), slated to start parts-sequencing work in 2028 and expand to parts assembly from 2030. The 63-second clip reposted by ZappyZappy7 is the official demo: the design favors necessary-and-sufficient function and manufacturability over anatomical fidelity.