RoboPartyHumanoid
RoboParty Roboto Origin Open-Source Bipedal Humanoid
Overview
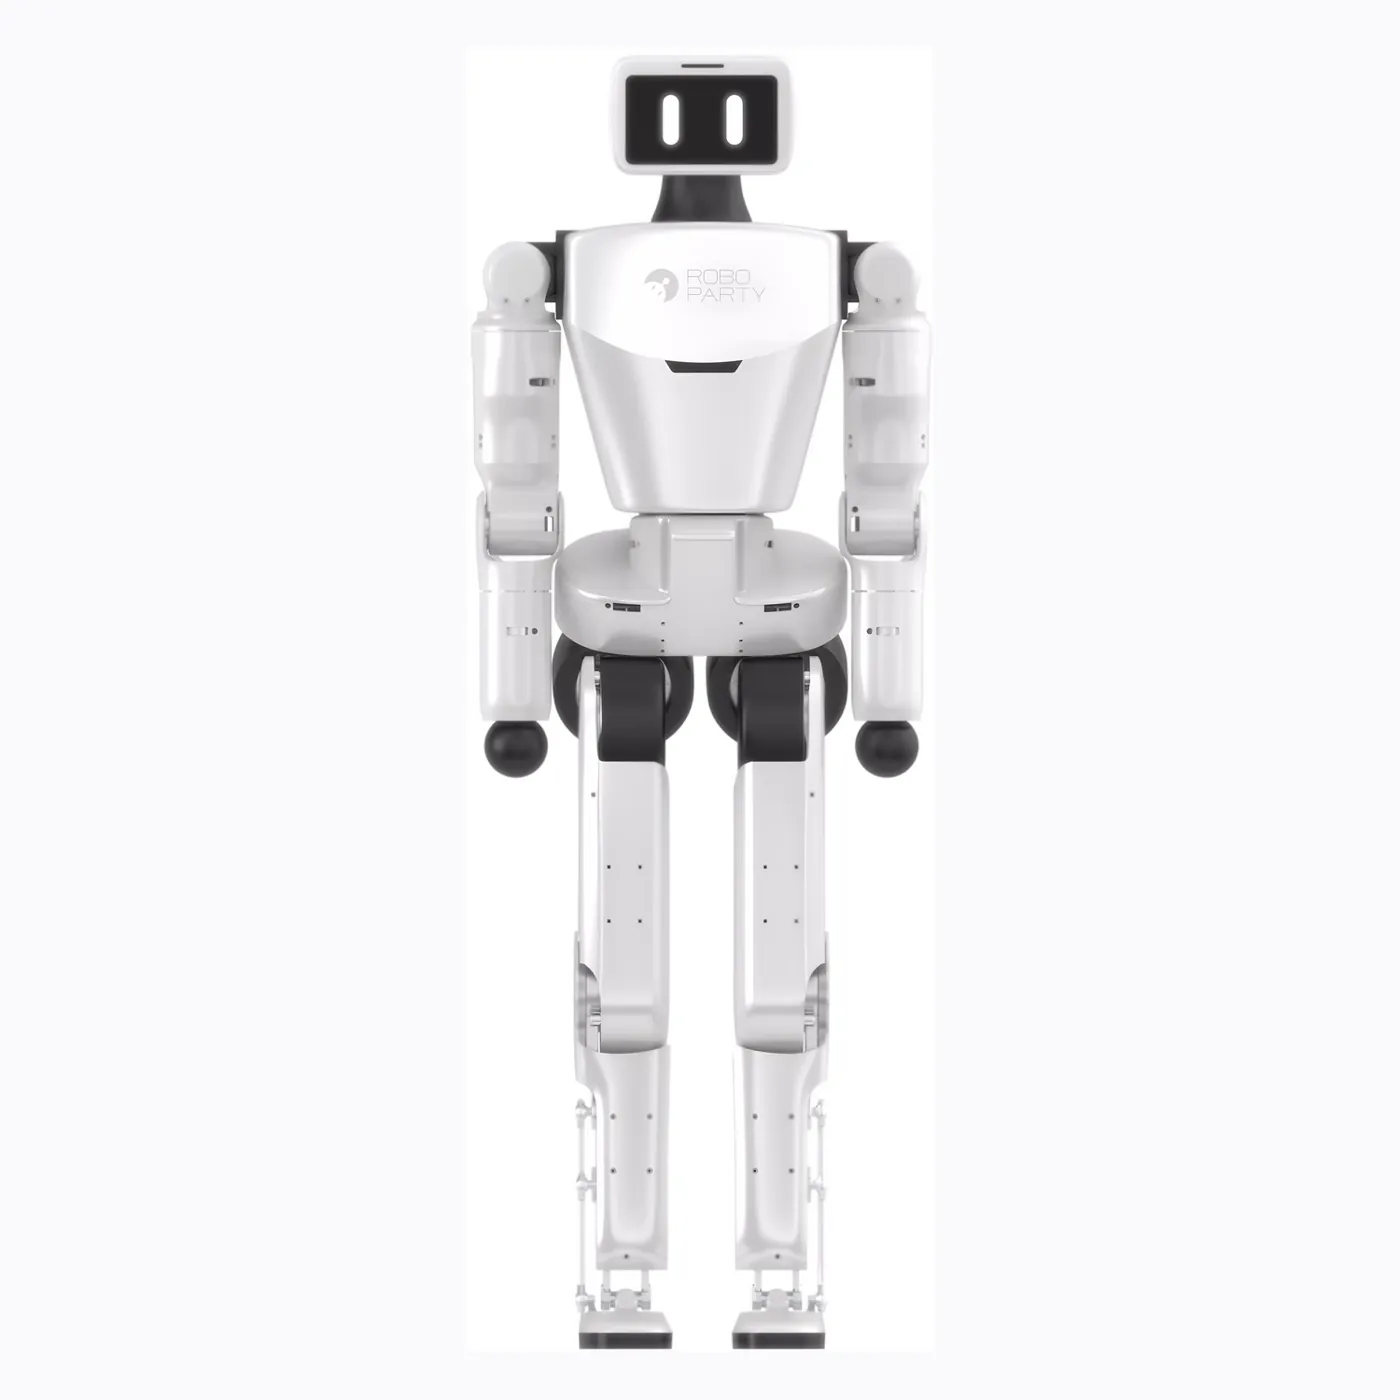
Roboto Origin ("Luobotou prototype") is RoboParty's (Shanghai) fully open-source bipedal humanoid prototype platform for makers, research and education: about 1.25 m tall, 34 kg, 23 DoF (6 per leg, 5 per arm plus waist), 250 mm thigh, 300 mm shin, 440 mm arm; leg joint peak torque 120 N-m and arm 27 N-m with top speed around 3 m/s; 48 V 15 Ah battery for over 2 h runtime; industrial CNC parts with parallel ankle and human-like offset joints; optional Intel D435i depth camera and 3D LiDAR; RDK X5 or Orange Pi 5 Plus main computer on Ubuntu 22.04 RT kernel. Full-stack open source covers CAD/PCB/BOM, embedded firmware, Isaac Lab/RSL-RL/AMP training, ROS 2 deployment with Python SDK, plus URDF/MJCF models and complete documentation.
Specifications
| Degrees of Freedom | 23 DOF( 6 5 ) |