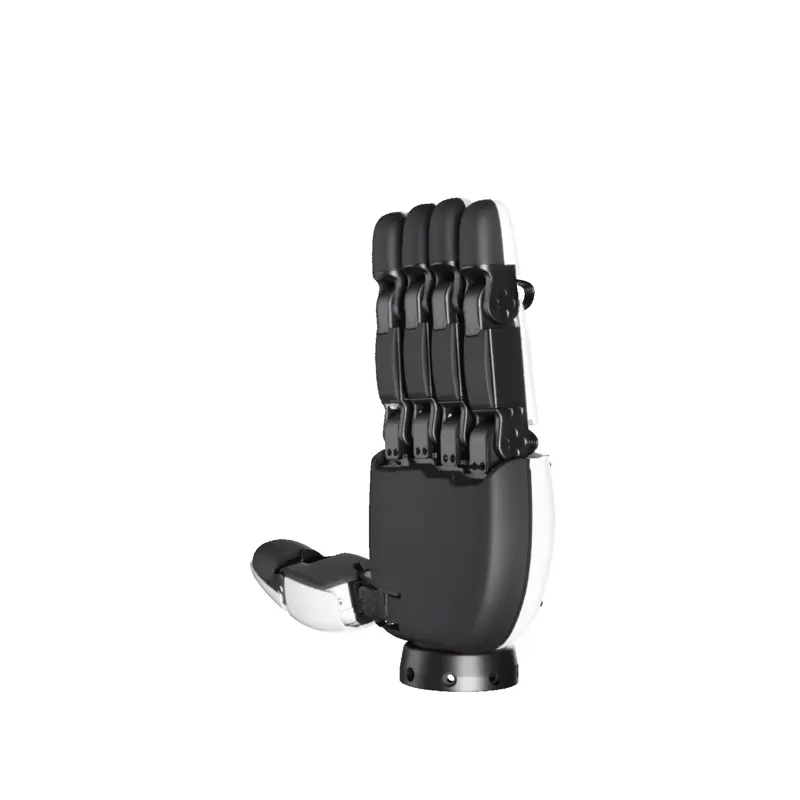
Fully direct-driven five-finger hand from RobotEra at 1100 g with 12 active DoF (thumb and index 3 each, others 2), ±0.20 mm fingertip repeatability, 5 kg+ per finger and 25 kg+ whole-hand lift. A 270° wrap-around tactile array with 120 points per finger at 0.05 N resolution returns three-axis force and temperature; 83 Hz whole-hand control rate, ≤0.1 N·s/m back-drivable damping and one million no-load cycles.
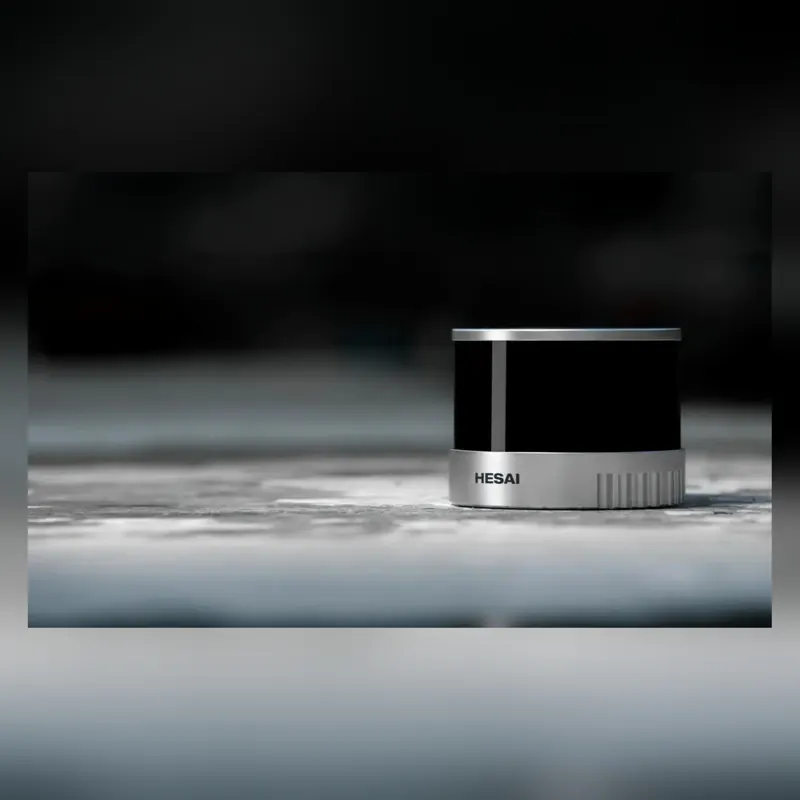
The Hesai XT32 is a 32-beam mid-range mechanical LiDAR: 0.05-120 m with true zero-blind close-range detection, 360°x30° FOV, 320k points/s (single return), 0.18°x2° angular resolution, 0.5 cm (1σ) precision and ±1 cm accuracy in an 800 g, H76 x Φ103 mm body with over 30,000 h design life, widely used on AGV/AMRs, delivery robots and high-precision mapping.
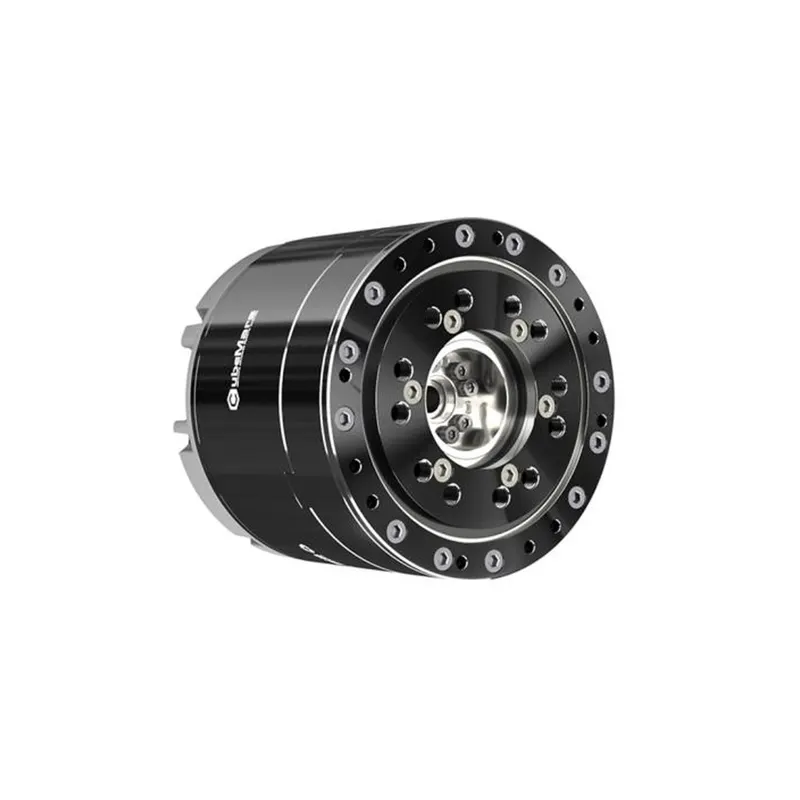
High torque-density integrated joint from CubeMars (Sanrui Intelligent) for humanoids and exoskeletons: 74 N·m rated / 222 N·m peak at only 1396 g (159 N·m/kg); 48:1 planetary reduction with 7 mm hollow bore, dual 21-bit magnetic encoders, integrated FOC driver, dual CAN, 48 V at 6 A rated / 18 A peak, 28 RPM rated, 12 arcmin backlash, listed at CNY 4888.
Integrated joint combining reducer, frameless torque motor, servo driver and 14-bit absolute encoder; mass-produced on the Lite3 quadruped and built for humanoid development. J60-10 reaches 56.48 Nm/kg torque-to-weight with temperature protection and CAN/serial tooling.
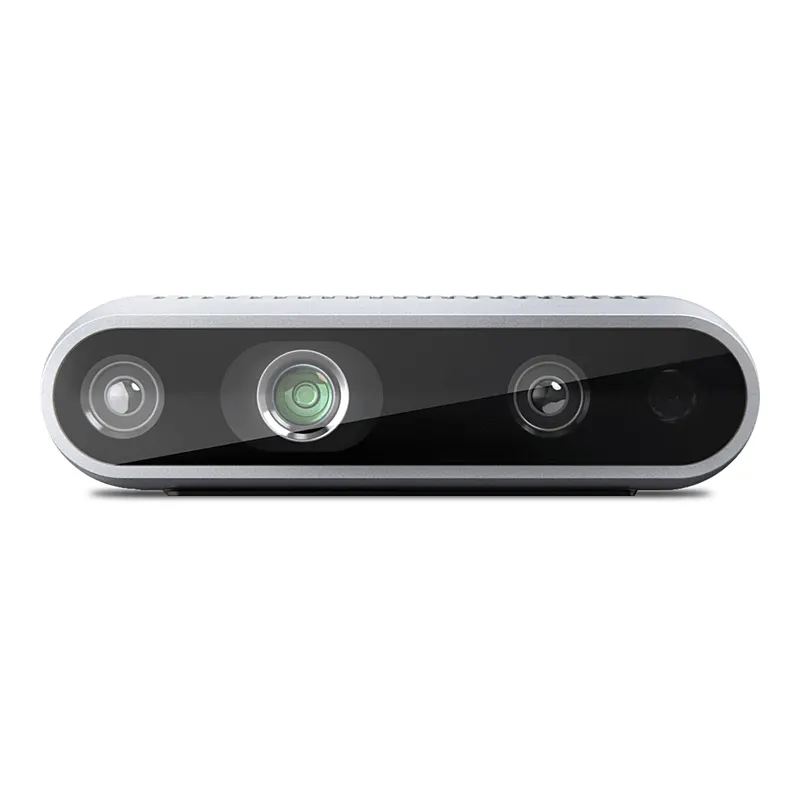
IMU-enhanced version of the classic D435: 50 mm baseline active stereo, 280 mm Min-Z @720p and ~10 m range, depth up to 1280x720@90fps, RGB 1920x1080@30fps, built-in 6-axis IMU for VIO/SLAM, USB-C power and data in a 90x25x25 mm / 75 g body - the install-base benchmark for robot arms, drones and mobile robots.
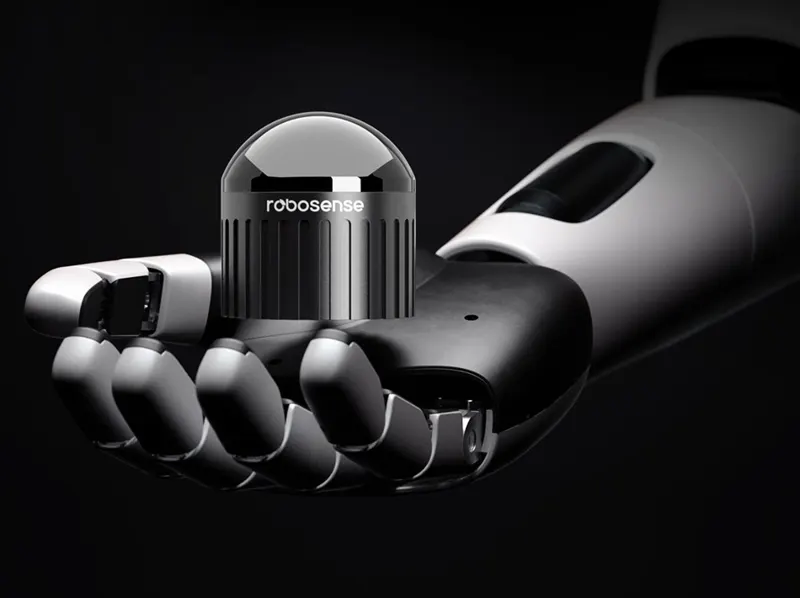
The world's first 192-beam hemispherical digital LiDAR, built on VCSEL emitter chips and a high-sensitivity SPAD-SoC digital detection architecture with chip-based transceivers and lossless echo data. A 360°x90° hemispherical FOV covers a 60 m radius at 1.72M pts/s with 1cm@1σ precision; just φ60xH63 mm, <240 g and <8 W with an integrated IMU. Structured, algorithm-friendly point clouds serve SLAM, obstacle avoidance and navigation for courtyard, quadruped and delivery robots in all weather.
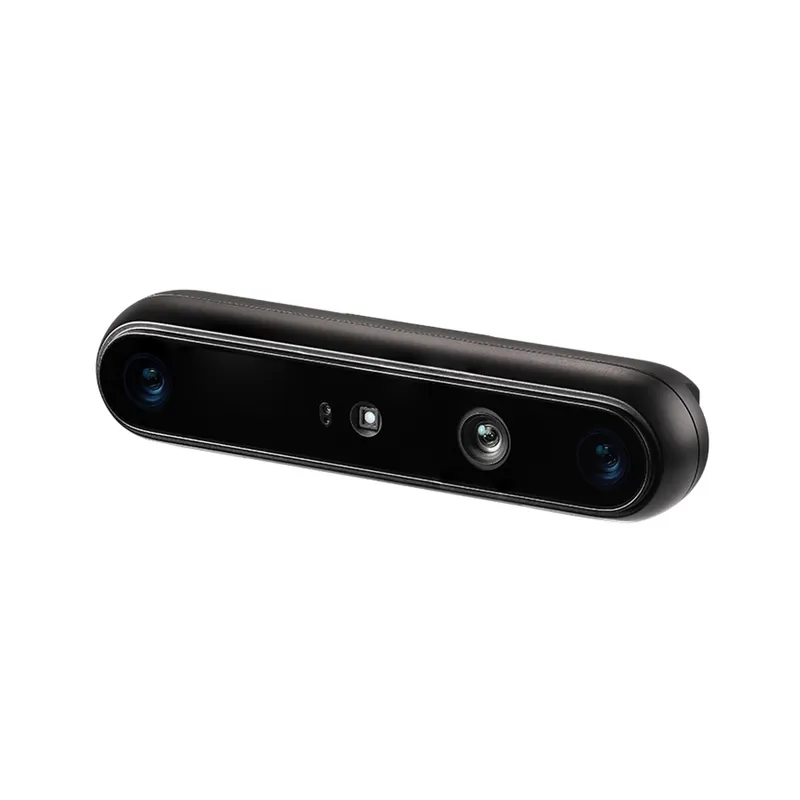
New-generation all-scenario stereo 3D camera in the Gemini 330 series, built on Orbbec's in-house MX6800 depth engine with an active-passive fused imaging system for indoor and outdoor use under sunlight, rated IP65. Recommended range 0.25-6 m, depth up to 1280x800@30fps with global shutter, USB 3.0 Type-C power and data in a 133 g body, for robots, AMR, industrial and outdoor applications.
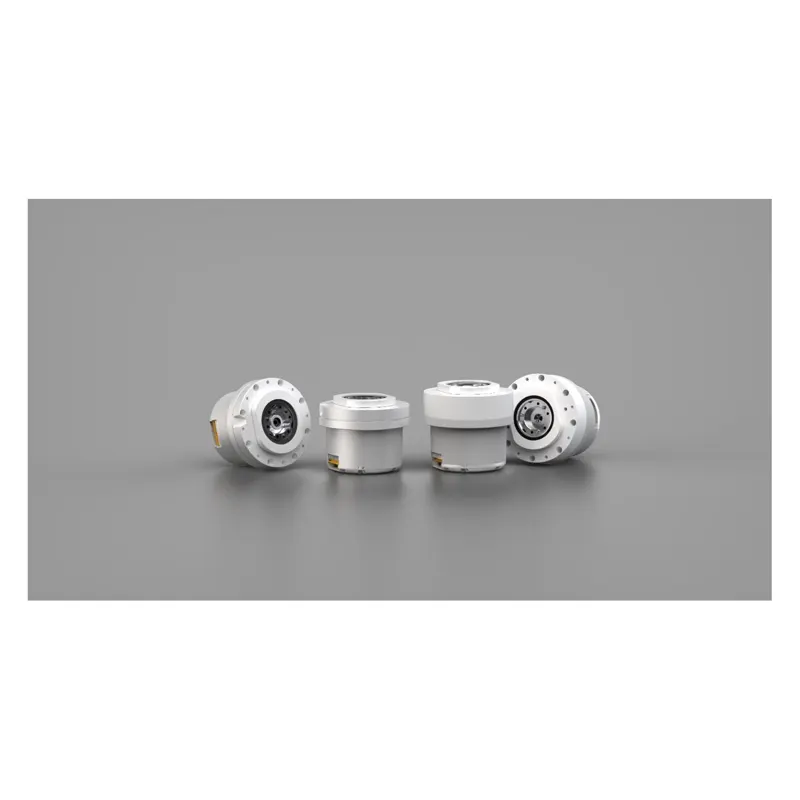
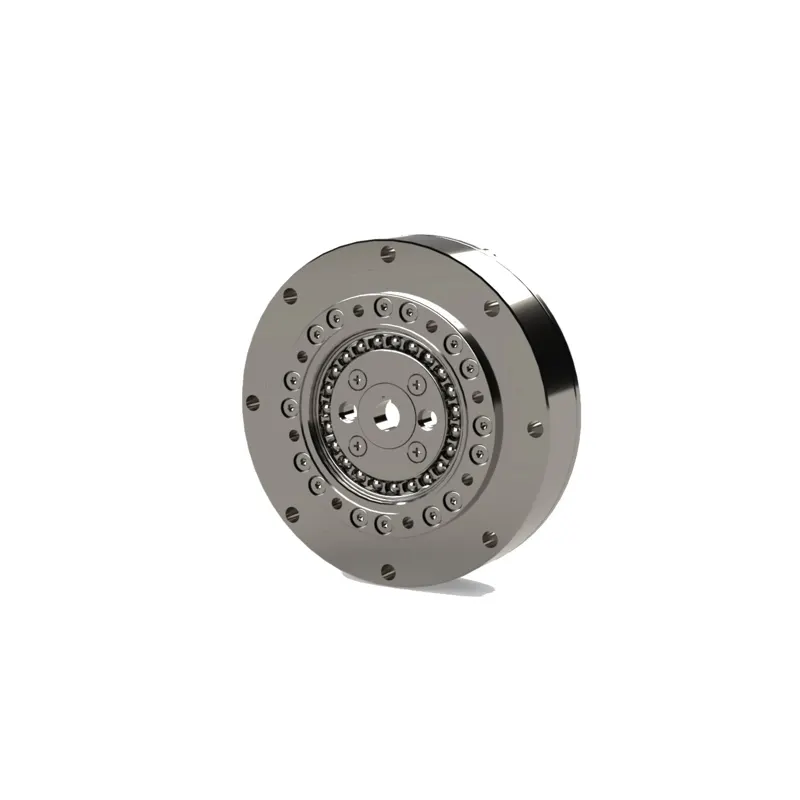
Ultra-flat strain wave gear built for tight axial space, about 50% shorter than the standard LHS/LHSG series, with a large hollow bore for cable routing. It keeps high rigidity, ultra-low backlash and strong load capacity across frame sizes 14-40 and ratios 50-160, rated 3.7-206 N·m, for humanoid robots, robot joints, PCB equipment and machine tools.
Lightweight five-finger dexterous hand from Agibot at ≤500 g with 10 active / 16 total DoF, 0.5 mm repeatability, 5 N typical fingertip force and 1 kg typical / 2 kg max palm-up load on a 5 cm rigid object; CANFD/RS485 interfaces, with 400+ tactile points on the tactile variant.
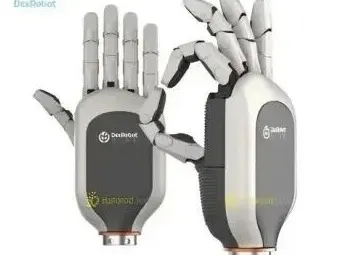
DexRobot hand for robotic manipulation and grasping research.
Sarcomere Dynamics high-DOF hand for teleoperation and research.
Korea University of Technology research hand for academic R&D.