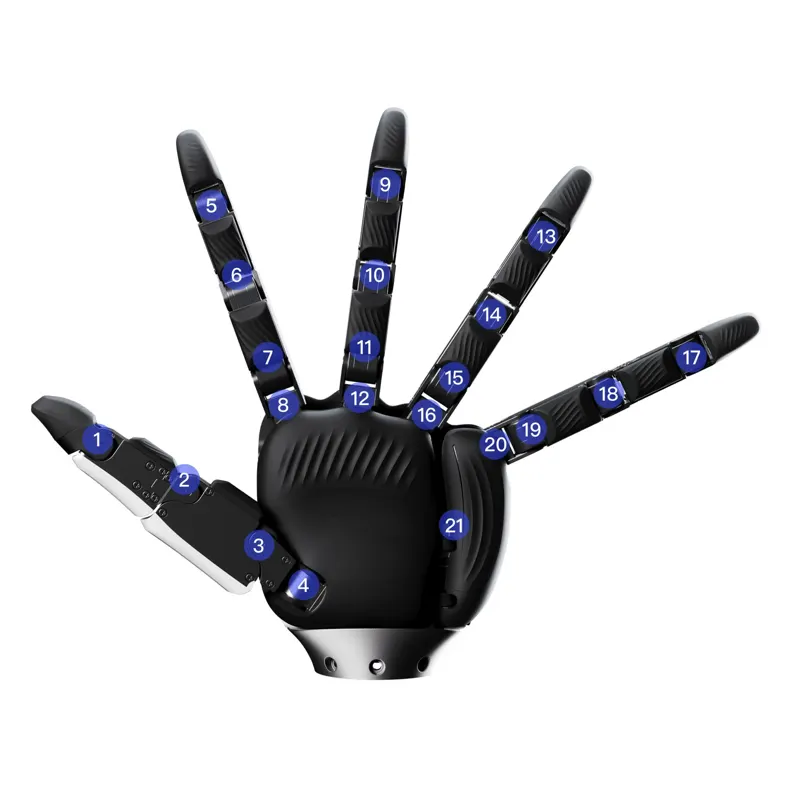
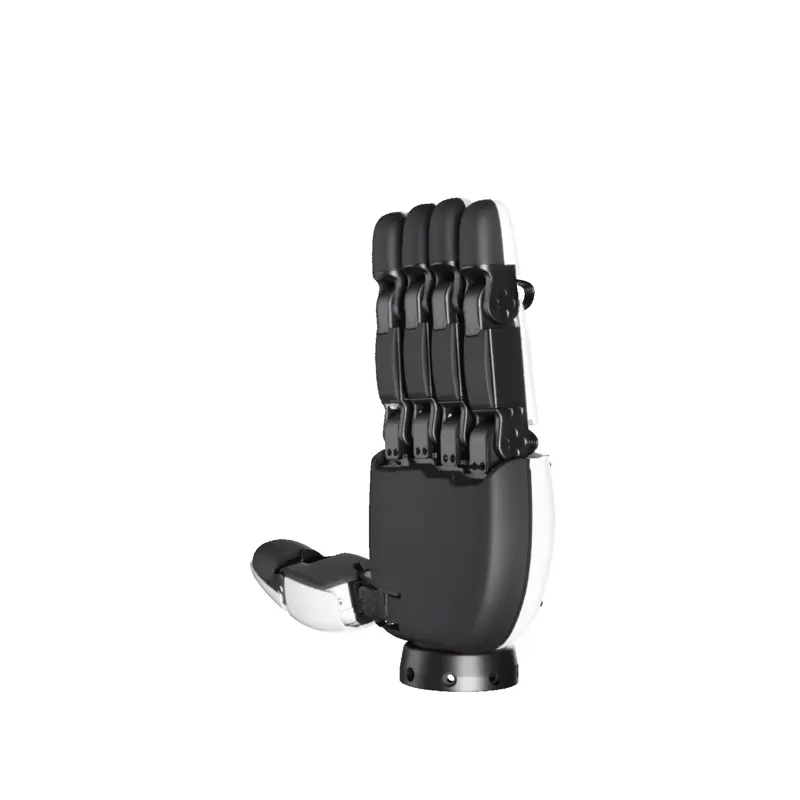
Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.
COMPONENT
Fully direct-driven five-finger hand from RobotEra at 1100 g with 12 active DoF (thumb and index 3 each, others 2), ±0.20 mm fingertip repeatability, 5 kg+ per finger and 25 kg+ whole-hand lift. A 270° wrap-around tactile array with 120 points per finger at 0.05 N resolution returns three-axis force and temperature; 83 Hz whole-hand control rate, ≤0.1 N·s/m back-drivable damping and one million no-load cycles.