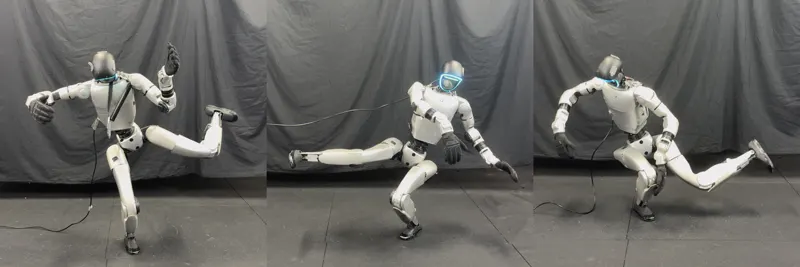
First Deployable Dynamic-CoM: A Unified Policy and Method-Agnostic Benchmark for Humanoid Single-Leg Balance
FDDC embeds the first deployable dynamic center-of-mass (xCoM) observation directly into the on-hardware actor and pairs it with a reward library translated from human postural control, holding clean single-leg balance on 86 of 90 motions and transferring to a real Unitree G1.
Yikai Zhou, Xingyun Wang, Jieming CuiAug 1, 2026
xCoMSim-to-RealUnitree G1Aug 1, 2026