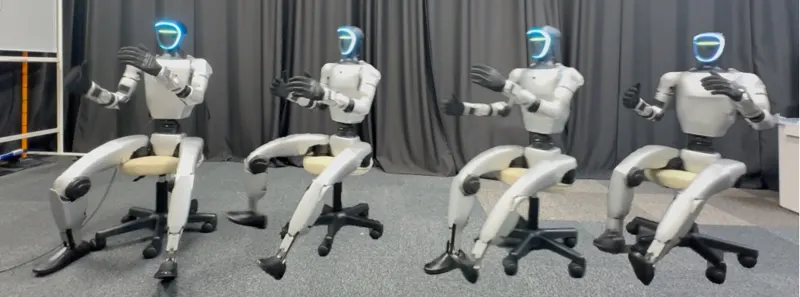
Humanoid Seated Locomotion on Passive Mobile Chair
Research on omnidirectional seated locomotion for humanoids on passive chairs. Policies use proprioception only, outperforming standing in tracking. Analyzes regularization effects on convergence.
Kango Yanagida, Kazuki Miyazawa, Takato HoriiAug 28, 2026
HumanoidSeated LocomotionControl PolicyAug 28, 2026