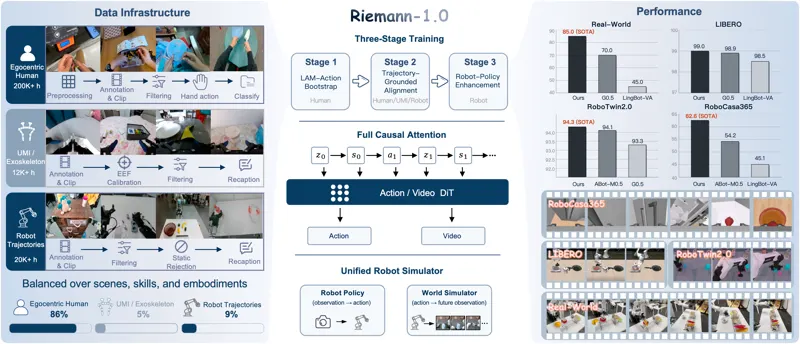
Riemann Dynamics releases Riemann-1.0: a fully causal autoregressive World Action Model that unifies executable robot policy and action-conditioned world simulation in one architecture. Through progressive pretraining on 232K+ hours of heterogeneous embodied experience, it achieves SOTA on LIBERO (99.0%), RoboTwin 2.0 (94.3%), RoboCasa365 (62.6%), and real-world manipulation (85.0% SR).
BLOG