Haozhi Robot Joint Module
Vendor: Haozhi
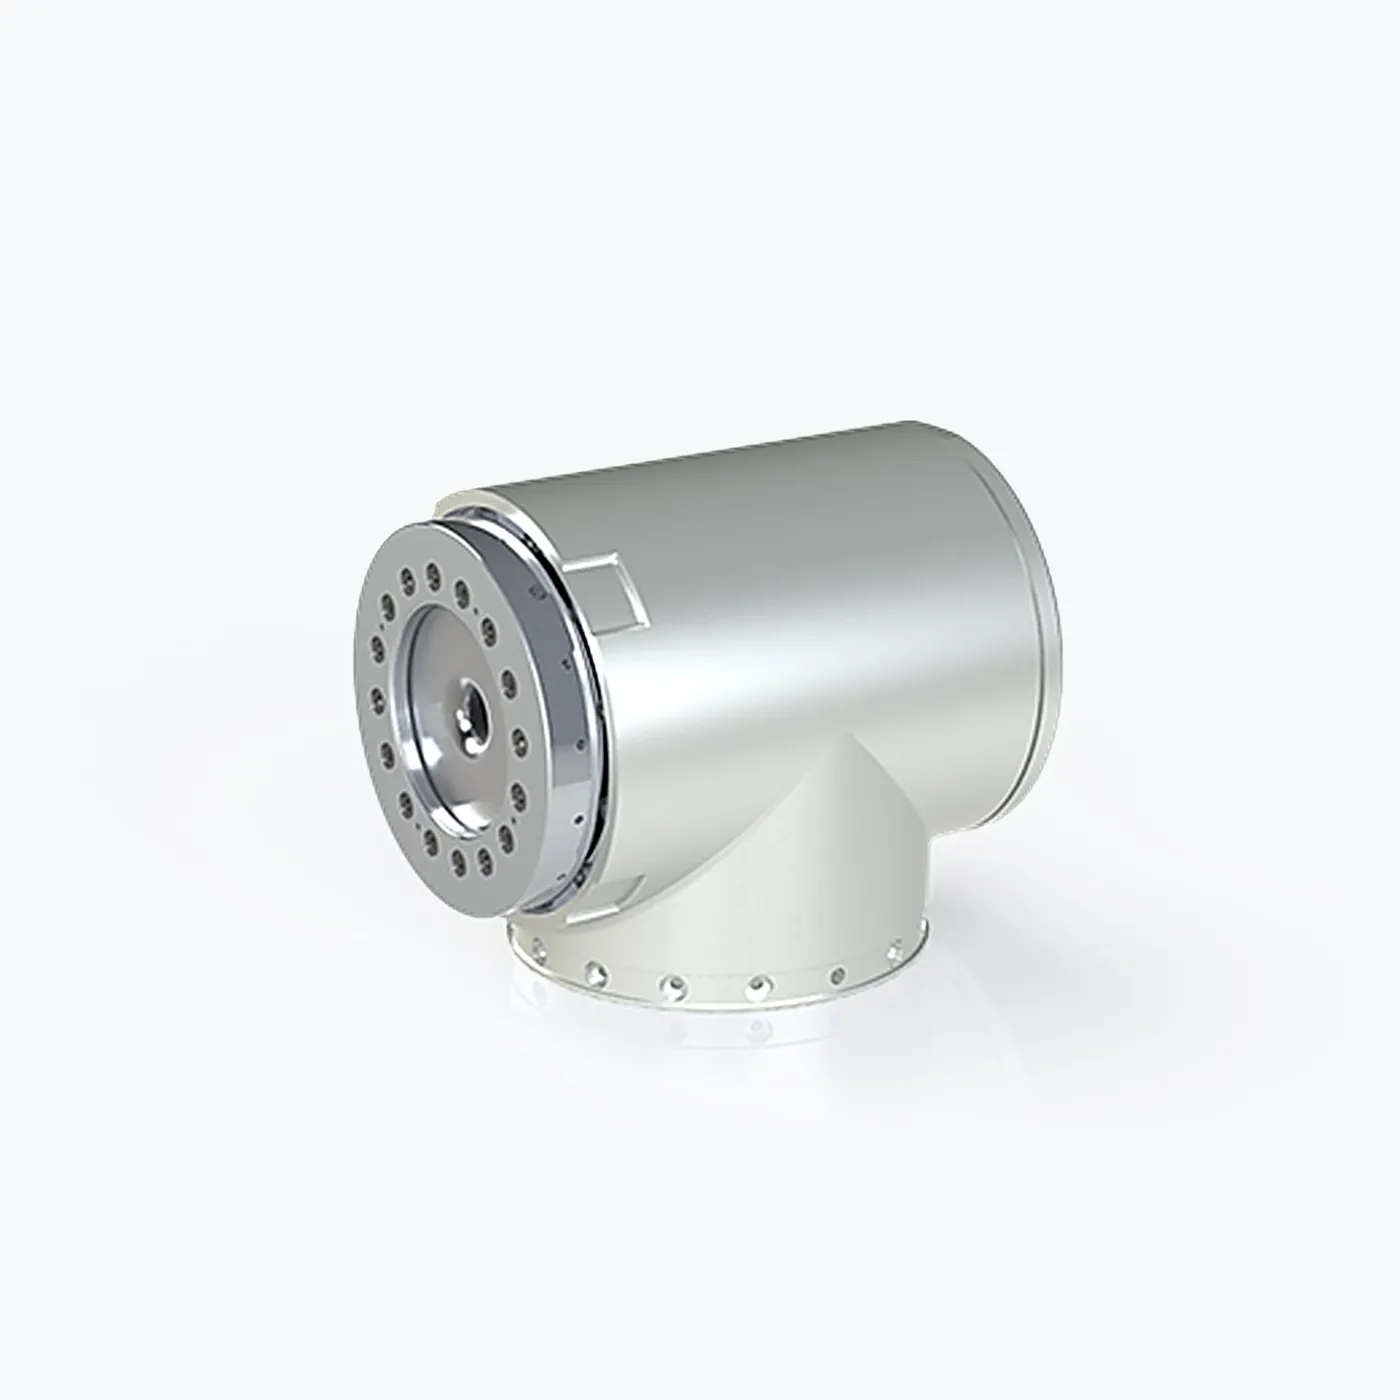
Haozhi integrated robot joint module in six sizes (14-40), combining a frameless torque motor, high-stiffness harmonic reducer, dual absolute multi-turn 18-bit BISS-C encoder and large-hollow low-voltage drive; ratios 50-160, peak torque 23-841 N.m with 3.5x overload, positioning <0.015° and repeatability 0.003°, EtherCAT/CANopen daisy-chain, 48 V supply with 24 V STO/SBC safety, friction brake, 12/18 mm through-bore, torsional stiffness 1.1-41 Nm/arc-min; for collaborative and humanoid robot arms.
| Bus | EtherCAT / CANopen, daisy-chain |
| Brake | Friction damping brake |
| Models | 14 / 17 / 20 / 25 / 32 / 40 |
| Supply | 48 V ±10%; 24 V I/O STO/SBC |
| Weight | 1.1 - 9.3 kg |
| Encoder | Dual absolute multi-turn, 18-bit, BISS-C |
| Overload | 3.5x |
| Dimensions | Ø70×98.55 mm (14) to Ø170×144.9 mm (40) |
| Peak Torque | 23 - 841 N.m by model |
| Through Bore | 12 mm (14), 18 mm (17-40) |
| Repeatability | 0.003° (≤±10″) |
| Reduction Ratio | 50 - 160 by model |
| Rated Output Torque | 7 - 382 N.m @2000 RPM input |
| Torsional Stiffness | 1.1 - 41 Nm/arc-min |
| Positioning Accuracy | <0.015° (≤±40″) |